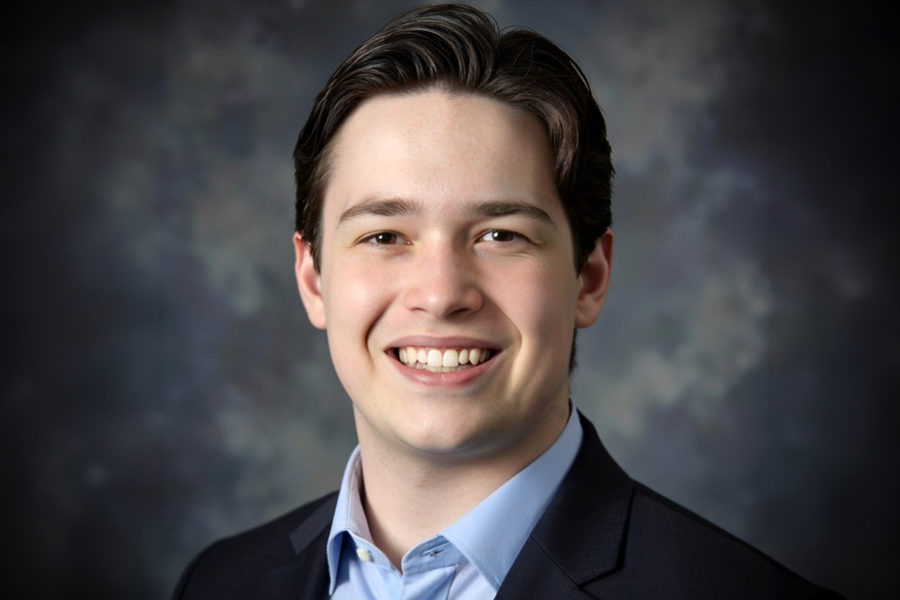
I'm an Honors Mechanical Engineering student at the University of Connecticut, concentrating in Dynamic Systems and Control. I'm especially interested in robotics, mechatronics, and
combining mechanical design, electronics, and programming to solve real-world problems.
Through hands-on projects, engineering coursework, and UConn's robotics teams, I'm building experience in mechanical design, simulation, programming, and robotic systems while
continuing to explore new technologies and engineering challenges.
My engineering experience includes mechanical design, CAD modeling, structural analysis using ANSYS Workbench, and programming with Python, MATLAB, and Arduino. Through coursework
and independent projects, I've gained practical skills in engineering analysis, simulation, and sensor-based systems.
Beyond the classroom, I'm a member of UConn's Underwater Robotics Club Float Team, where I collaborate on the development of a robotic system designed to maintain controlled underwater depths.
I also serve as Co-Founder and Secretary of UConn's VEX Robotics Club, combining my technical interests with leadership and teamwork as I prepare for a career in mechanical and
electromechanical engineering.
My engineering interests focus on robotics, mechatronics, precision engineering, and control systems. I'm particularly interested in how mechanical
design, electronics, and software come together to create advanced, reliable systems.
I hope to build a career developing innovative mechanical and electromechanical technologies. I'm especially drawn to opportunities involving
hands-on design, simulation, testing, and collaborative problem-solving.
University of Connecticut
Bachelor of Science in Mechanical Engineering
University Honors Program
Concentration: Dynamic Systems and Control
Pursuing Honors Scholar in the Major
Cumulative GPA: 3.61 / 4.00
Expected Graduation: May 2028
A selection of hands-on engineering projects involving robotics, mechanical design, programming, and simulation. These projects demonstrate my experience applying engineering principles to real-world technical challenges.
As a member of UConn's Underwater Robotics Club Float Team, I collaborate on developing a sensor-equipped robot designed to maintain controlled depths through variable buoyancy, mechanical design, and sensor integration.
View UConn's UWRC →Applied SolidWorks and ANSYS Workbench to mechanical modeling and engineering analysis through coursework. Used FEA to evaluate stress, deformation, reaction forces, and structural behavior under applied loads.
Explore My GitHub Portfolio →Designed, built, and programmed an Arduino-based ultrasonic distance sensing system using a microcontroller, sensor, and LED feedback. Also developed Python and MATLAB tools for engineering calculations and robotics-related analysis.
View on GitHub →My technical background combines mechanical design, engineering analysis, programming, and robotics. Through coursework and hands-on projects, I'm developing skills in CAD, simulation, sensor-based systems, and mechanical engineering applications.
Through engineering organizations, robotics competitions, and student leadership, I've developed skills in teamwork, technical problem-solving, and communication while contributing to the UConn engineering community.
Explore my engineering projects and programming work on GitHub, or connect with me on LinkedIn for more information about my academic and professional experience.
Connect with me professionally through LinkedIn, explore engineering projects on GitHub, or download my resume for additional technical experience and project information.